TOILET CLEANING ROBOT
TCRClean. Dry.
Ready for the next.
A robotic arm for the everyday washroom routine. TCR combines directed cleaning, a drying cycle, and connected controls for rail washrooms.
Prototype system · Original development imagery
01 / THE CLEANING ARMHRL ENGINEERING
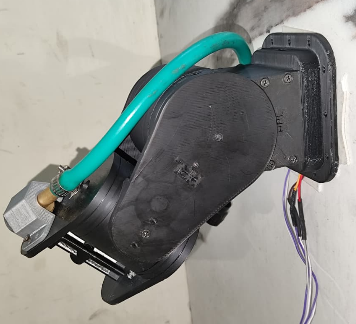 Compact arm. Directed spray. Controlled movement.
3–4 LNormal cleaning
5–6 LIntense cleaning
3–4 minDrying cycle
3 modesAutomatic · App · Scheduled
Approximate development figures. Water use and drying time depend on installation and operating conditions.
ONE CONNECTED ROUTINE
A cleaning cycle.
With drying built in.
From checking occupancy to returning the washroom to service, each stage has a place in the sequence.
- 01
Check & secure
Presence and door-lock sensing check that the washroom is empty before a cycle begins.
- 02
Spray & sweep
Directed spray and arm movement cover the basin, walls, edges, and corners.
- 03
Dry the space
A blower circulates air to remove residual moisture after cleaning.
- 04
Return to ready
The sequence completes, the door unlocks, and the system returns to idle.
CONTROL THAT FITS THE ROUTINE
Three ways
to start a clean.
01 Automatic cleaning +
Presence sensing checks when the user has left. The system can initiate a cleaning cycle after a flush or when the washroom becomes empty.
02 App control +
Use the mobile interface over Bluetooth or Wi-Fi to choose cleaning modes and control arm movement and pump operation for maintenance or special cleaning needs.
03 Scheduled cleaning +
Run at predefined times. If the washroom is occupied, the cycle is postponed until the space is empty.
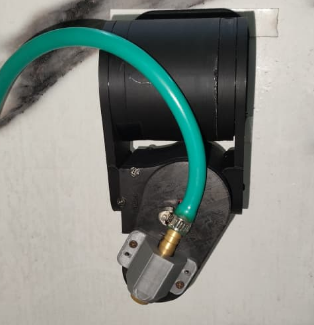 TCR arm assembly · Prototype installation
INSIDE THE SYSTEM
Purposeful hardware.
Connected control.
An ESP32 controller coordinates the servo-driven arm, pump, and occupancy inputs. The cleaning and drying assemblies work as parts of the same washroom routine.
- Presence sensingUltrasonic sensing and door-lock input
- Directed cleaningServo movement and controlled pump operation
- Drying assemblyBLDC blower for the drying stage
- Connected operationWi-Fi and Bluetooth app interfaces
THE DEVELOPMENT CONFIGURATION
TCR at a glance.
Specifications described in the supplied development presentation.
- Application
- Arm-based toilet cleaning for rail washrooms
- Operating modes
- Automatic, app-controlled, and time-scheduled
- Normal cleaning water use
- Approximately 3–4 litres
- Intense cleaning water use
- Approximately 5–6 litres
- Drying time
- Approximately 3–4 minutes
- Control platform
- ESP32 with Wi-Fi and Bluetooth
- System supply
- 12 V / 5 A DC, as specified in the presentation
- Coach supply integration
- 110 V DC conversion to the required system supply
- Cleaning pump
- 3 L/min nominal flow; 6–12 V DC
- Occupancy inputs
- Ultrasonic sensor and door-lock sensing
Final configuration and performance require installation-specific engineering and validation. OTA firmware updates, cloud monitoring, and battery backup are development extensions.